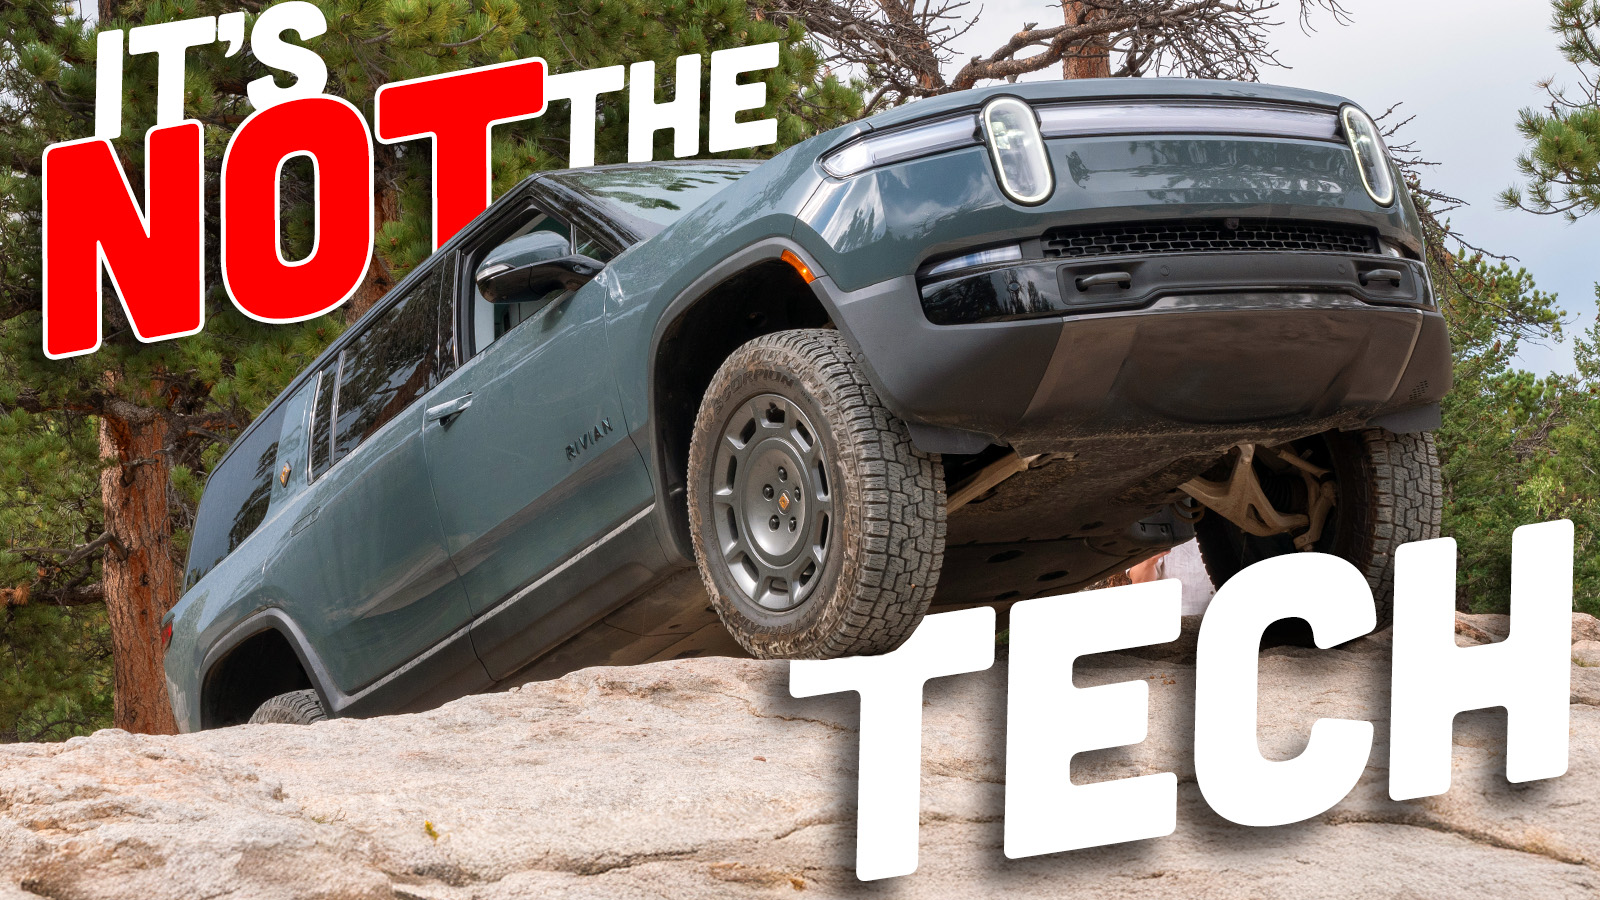
Back in 2021 during Rivian’s very first media launch, I got to test out the company’s Quad Motor four-wheel drive system. What I found is that, on paper, it’s the greatest four-wheel drive system ever, but in reality it was far from it. Tires flared up as the software was unable to properly anticipate traction conditions, and the heavy R1T slid sideways as it kicked rocks out from under its tires. In general the whole thing was far, far more dramatic than it should have been. Fast forward five years and I finally had a chance to drive the newest version of the Quad Motor system. Here’s what I learned.
This past weekend I flew to Colorado to hang out with a bunch of my wife’s friends, their husbands, and their babies. It was a family weekend filled with crying babies, crazy dogs, lots of toys, and pure and utter chaos. I loved every minute.


On the first full day of the trip, the moms took the kiddos… somewhere. I probably should have paid closer attention to the agenda, but the point is: We four dads were on our own. Two of the dads went out to the golf course, while the other dad and I — both a bit younger and both significantly less interested in spoiling a good walk — decided to take the press vehicle Rivian had kindly loaned me to some local off-road trails, as Colorado has some absolute gold in them hills.
I’m lucky enough to know Tommy and Roman from The Fast Lane Car/Truck/Off-Road/Classics, a fantastic YouTube channel/network that you should all watch if you don’t already. Tommy told me to meet him at the Overland Expo that was happening that day, then he’d buy me and the other dad lunch, and we’d hit the trails.
View this post on Instagram
Tommy, the kind person that he is, directed me straight to the Toyota booth at the Expo to point out the coolest thing there — something that he knew would be something Autopian readers would appreciate. It was a Toyota Hilux Champ-based 4×4 concept vehicle shown above, as some of you may have read the other day.
Anyway, after the show and after eating bread pudding for lunch (since the other dad, Mickey, and I had foolishly picked up some pulled pork sandwich “snacks” at Buc-ee’s on the way to the Expo), Tommy — driving a Jeep Wrangler Willys 392 — took us west into the mountains, where we met his dad Roman.
I followed Tommy as he led the four of us in two vehicles to one of TFL’s most popular off-road test trails.
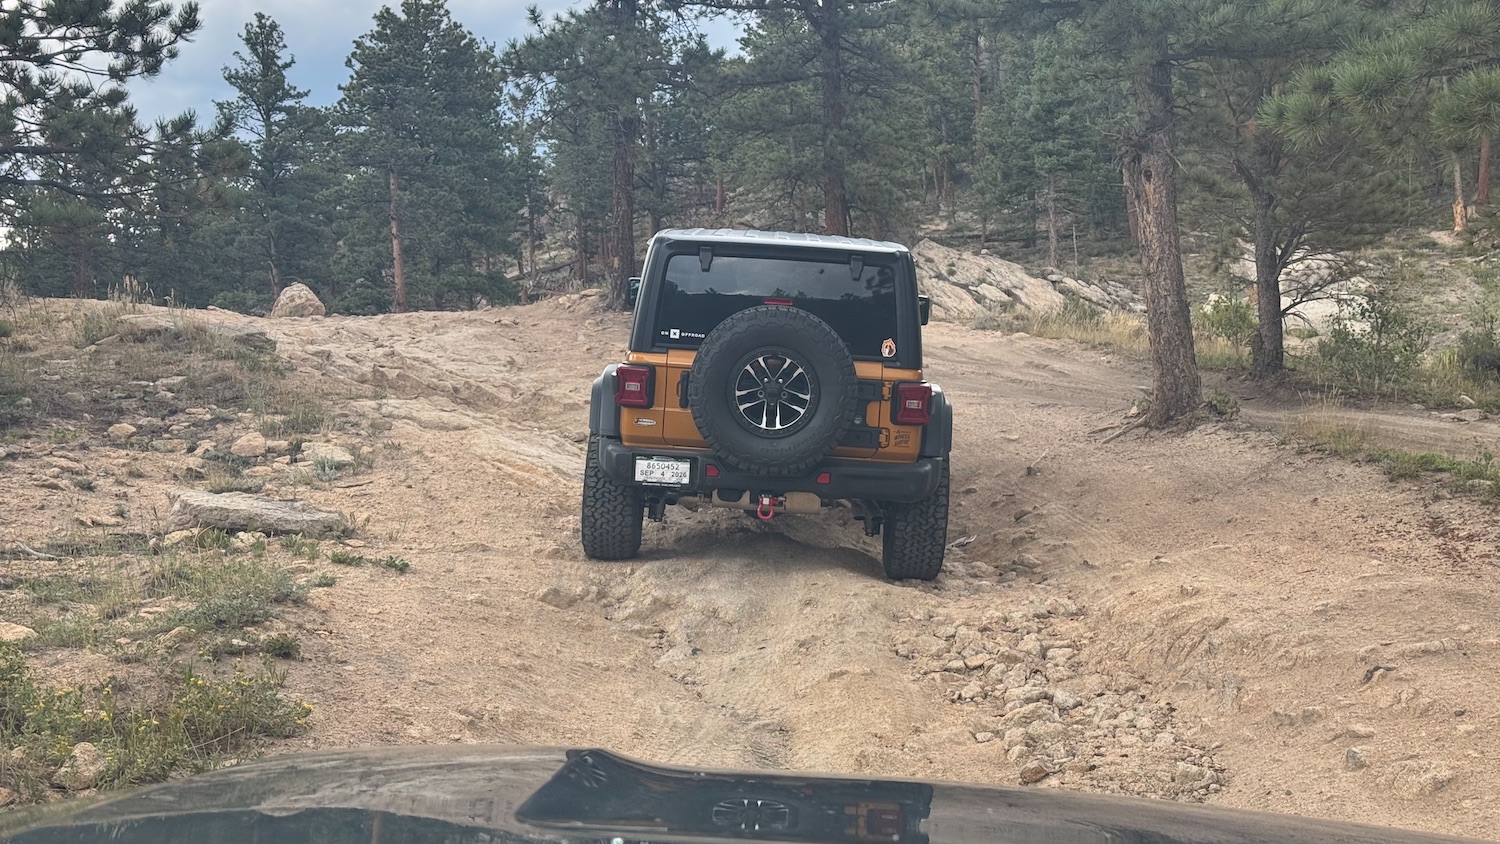
This was rocky terrain, which was perfect, as my aim in borrowing this Rivian R1S was to test the Quad Motor system, since Rivian told me during the R2 media event that the control system has been significantly updated since I’d driven that R1T way back in 2021.
Why The Quad Motor System Isn’t Ideal For Rock Crawling
To give you an idea why I was so intrigued by this updated system, you have to understand some of the challenges that such a complex system introduces. To the layperson, the idea of a four-motor powertrain/drivetrain sounds amazing, as it should allow for extremely granular adjustment of the torque/speed of each wheel to suit the terrain — certainly more granular than clutches, brakes, and other mechanical limited-slip systems found on traditional off-roaders. In reality, though, the R1T I drove five years ago tended to spin/flare up its wheels more than one would want over rocky terrain, making it difficult for a driver to maintain control over particularly technical obstacles and tending to tear up the trail even more than you’d expect a 7,000 pound SUV to.

I described the complexity of the four-motor four-wheel drive system in that old review, using a thought exercise:
To climb that grade at a given velocity (we’ll call it 2 MPH), the vehicle requires a certain amount of torque at the wheels. Imagine you’re driving a Jeep Wrangler Rubicon up this grade, and your foot is pressing the accelerator pedal a given amount, causing you to cruise up the grade at a constant velocity.
Now let’s say the passenger’s-side front wheel hits an ice patch and loses all grip, but the driver maintains the same pedal position. Will the tire slip (i.e. will its tangential speed exceed the vehicle speed)? The answer is: only if the three other tires — with which the tractionless tire is mechanically linked — cannot make up for the lost traction.
In other words, if the three tires with grip have enough traction such that the torque at the three wheels equals the required total wheel torque to ascend the grade, the vehicle will keep moving at a steady rate, and the tractionless tire’s tangential velocity at the tread will likely equal close to the vehicle’s velocity. The ascent will be smooth.
Put more simply, let’s just model the Jeep Wrangler Rubicon’s driveline as one big axle with four tires on it. Torque is being sent through that big axle, and all four tires are spinning at the same rate because they share a common shaft. If one or two or three tires roll over ice, the giant axle will continue moving steadily so long as the friction coefficient between the ground and the tire(s) with grip is capable of producing enough torque against the tire to meet or exceed the wheel torque needed to ascend the grade. (Note: There will be a yaw moment depending upon which tires have grip).
With Rivian’s system, what happens? Well, let’s again say you’re climbing that same hill with the pedal depressed a certain amount. A given amount of current is being sent to the wheels, producing the requisite wheel torque to ascend the grade at 2 MPH.
Now let’s say the passenger’s side tire loses all grip; what happens? Well, the wheel torque there goes to zero, and the wheel slips until the vehicle can pull current from that motor; does the wheel torque at the other three wheels instantly increase like it does with a fully-locked ICE in order to maintain a steady vehicle speed? Not instantly. The vehicle’s electronics have to quickly send more current to the other motors with grip to keep the vehicle moving at a given rate.
How much current do you send each wheel? What if you send too much current to a wheel that doesn’t have quite enough grip, causing wheel-spin? As for the wheel without grip; should it keep spinning at a rate that corresponds with vehicle speed so that it doesn’t have to accelerate once it does get grip? If so, how do you know what the vehicle speed is?
Clearly this is complicated stuff, and getting four motors to mimic the controlled, smooth behavior of a fully locked conventional 4×4 drivetrain is not easy, even with torque command refresh rates in the triple digit-herz (>100 times a second).

Check out that old review, which includes a quote from Principle Engineer of Rivian’s Drive System Mason Verbridge talking about how the control system has to predict the friction coefficient between the tires and the surface, and use that information along with a vehicle reference speed to adjust torque to the wheels. From that story:
Think about that for a second. Rivian’s system has to not only predict the friction coefficient (which is constantly changing!) but it also has to figure out what the vehicle’s speed is, which isn’t easy to do if there’s slip at all corners.
[…]
Verbridge admits there are limitations to the system. “There’s a PID gain loop there… a control reaction time iteration time in your way,” he said. “To your point, it’s not gonna be perfect. How quickly can you go ‘I’m slipping. Stop.’ That’s your limit of the technology.” He notes that the system is quick, but admits that the wheels do flare up a “quarter turn at a time” before the control software brings the wheel speed down.
How Did The New Rivian R1S Quad Do Off-Road?
The Drivetrain
View this post on Instagram
The Instagram video above shows an obstacle that the guys at TFL call the Razor Rocks. You can see right away that the Jeep Wrangler’s solid axle suspension, which could offer significantly better suspension articulation if the front sway bars were unlocked, still did really well, almost flowing over the rocks. Admittedly, I had the R1S in its highest ride-height setting, which meant articulation wasn’t maximized and also the ride quality was rather harsh, but given the size of the R1S I needed as much clearance as I could get, and the R1S flexed well enough given its setup.

Compared to the Wrangler — whose drivetrain mechanically connects all wheels together and therefore avoids wheel flare-ups since each tire’s tangential velocity, whether it has grip or not, is always close to the vehicle speed — the Rivian struggled. Here is the R1S spinning its front left wheel, which is way up off the ground:

Let’s just say all four motors were sending equal torque to the ground as I was approaching the obstacle at 1.5 mph. Once this front left tire lifted off (or just before it), now that motor can no longer help propel the 7,000 pound R1S up the grade. This means the current to the other three motors has to increase to maintain speed, but what if one of them doesn’t have enough traction to handle the increased torque? Then it spins, and then we’ve got a bunch of spinning tires and a system that doesn’t really know how fast the vehicle is moving, so how do you prevent wheels from being spun up too fast?
Like I said, it’s tricky, and someone at Rivian definitely understands this feedback loop/control system way, way better than I. But the point is that, while rock crawling, this four-motor system is not as controlled as a fully locked traditional four-wheel drive system, which can send full engine torque to any single wheel with traction, and which rarely spins up the tires. The R1S’s front left tire, for example, was being spun up despite it having zero traction. The other wheels were not being sent enough torque to propel the vehicle, possibly because I was afraid of putting the pedal farther down, as this could have sent too much power to the ground and launched me forward uncontrollably.
You can see in that video above that the Rivian is trying to figure out the traction conditions, and while it obviously didn’t handle the obstacle as smoothly as the Wrangler, it did get the job done, and I felt like I was safe the whole time. In fact, I was using left-foot braking to try to maintain control, and the vehicle seemed to understand what I wanted. It was very slow to move me forward and up the grade, sure, but it felt methodical and it achieved the goal in a way that made me as the driver feel more comfortable than I felt driving that R1T five years ago at that press event.
One other thing I’d like to mention is that the four-motor system often finds itself confused on even rather simple terrain, especially downhill. As the tires lost grip, it seemed like the regenerative braking that was slowing the vehicle down by adding backwards torque was unable to pull that torque quickly enough, spinning the tires backwards.
Yes, the video above shows the wheels spinning backwards while the vehicle was moving forwards. This, of course, tended to make noise and move rocks, tearing up the trail more than necessary.
So in short: On the rocks, it seems improved, but still nowhere near as controlled as a traditional ICE 4×4 drivetrain.
The Suspension

The Rivian R1S’s suspension is a masterpiece. I’m not a huge fan of fully independent suspensions for rock crawling, mostly because solid axles tend to offer better articulation, durability, and simplicity. But the R1S is a supercar; it’s a 1,025 horsepower luxury machine that can handle far better than anything its size and weight should be capable of handling; solid axles would have made no sense in this application.
What Rivian managed to pull off with this fully independent suspension system is truly remarkable. Here are some of the changes for the new generation of the R1S:
R1S ride and handling advancements are achieved through new air springs with recalibrated front and rear spring rates, new dampers and a new hydraulic roll control system specifically optimized for R1S, similar to those found on supercars.
Yes, the R1S not only has air suspension, but it has cross-linked hydraulic roll mitigation that can force wheels up and down, leading to excellent wheel travel when you need it. You can see in the images above and below that the front left wheel is being forced down to keep it in contact with the rock:

Here’s a close look at that upper control arm drooping hard to get that tire down onto the terra firma:

Ride quality at max ride height isn’t amazing, since there’s not much droop, and the suspension articulation would get dog-walked by a Jeep Wrangler with its front sway bar disconnected, but still — this is a truly amazing off-road fully independent suspension, and as shown in this old Car and Driver video of the sibling R1T, that suspension flex can outdo even a dual solid axle Jeep Gladiator without sway bars disconnected:
The Verdict: What Really Makes The Rivian R1S Quad So Good Off-Road Is The Simple Things
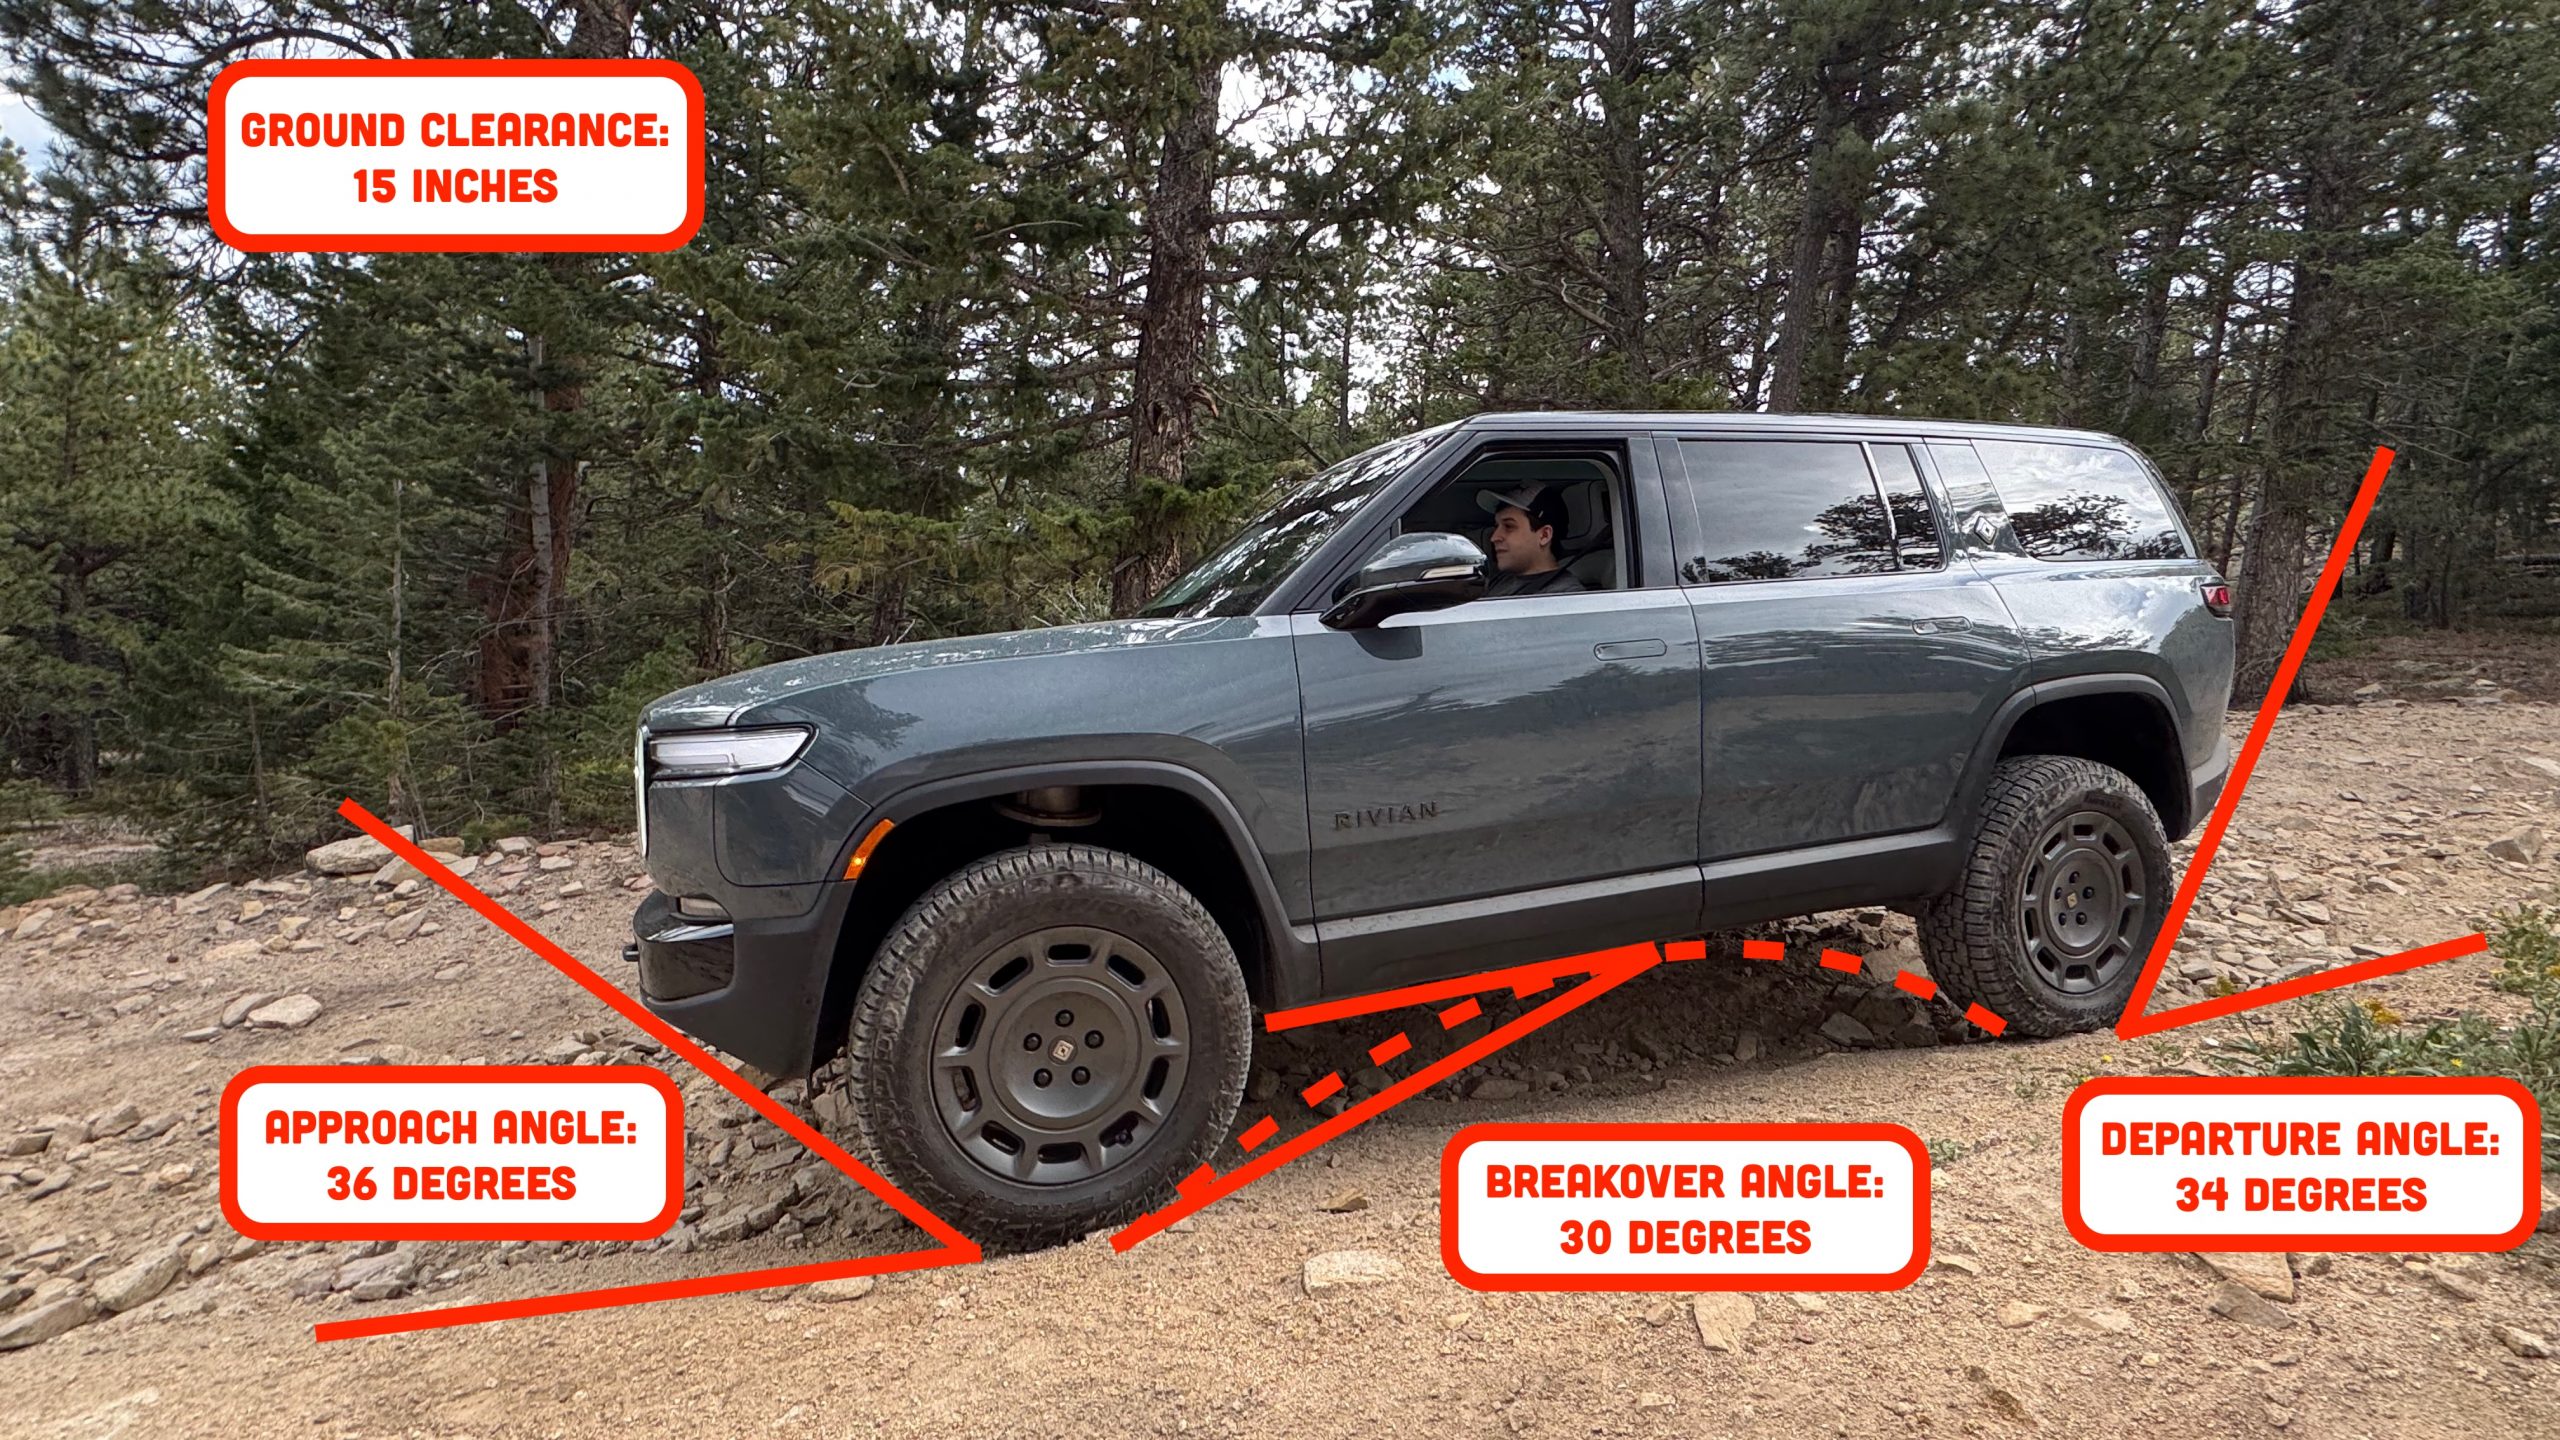
It’s not the Rivian’s fancy four-motor tech that makes it so good, it’s the thing you likely have heard me harp on and on about: “The single most important attribute of a capable off-road vehicle is favorable geometry.” I’ve probably typed that sentence a thousand times, but the R1S is proof positive.

While the vehicle isn’t huge for a three-row SUV, it is huge for a serious off-roader. But the R1S manages to hide that size, offering huge interior dimensions but still maintaining a ridiculous 36 degree approach angle, 34 degree departure angle, 15-inches of ground clearance, and 30 degree breakover angle. These figures mean the Rivian can get its tires up and onto even the steepest, toughest obstacles, and though the four-motor drivetrain takes a bit of buffering to figure out traction conditions, it does eventually get torque to the tires with traction.

And when it comes to off-roading, that’s half the battle. Get tires up onto things, keep the chin, belly, and butt from scraping, and (eventually) provide enough torque to wheels with traction to keep the thing moving along. And the Rivian just does it. I didn’t air down, I didn’t try to optimize ride height or regen settings, I just did the thing superior geometry allows you to do off-road: point and shoot.


Can someone explain to me why a setup like this doesn’t just try to mimic a locked axle 4×4 and apply the same power to all four wheels regardless of one wheel spinning? They seem to be trying to outsmart physics and losing.
I had the same thought, why can’t the computers just run all 4 wheels at the same RPM? Or with a dual motor setup, have basic locking differentials. The only thing I can think of is they have this functionality already for on-road traction control, so maybe they are trying to extend it into off-road.
Getting all 4 wheels to spin at the same RPM like a fully locked 4×4 is kind of what they’re trying to do. The problem is it’s a lot harder in practice than it sounds.
The motor speed depends on how much current you send it, so you can’t just say “same amount of current to each motor” or you’ll have wheels spinning wildly if they lift or lose traction. So the computer has to guess the traction conditions at each wheel, send the estimated current, check the wheel speed, then correct, which all takes time. On top of that, it doesn’t know which wheel speed is the correct one to try to match. It knows it’s supposed to be moving forward, but if 2 wheels lift and one’s on sandy rock and slipping, which wheel speed is the desired one?
So it has to go through all these calculations to vary current to each wheel and try to keep everything under control, and then the truck moves forward a foot, lifts a different wheel, and suddenly everything is out the window and it has to start over.
Basic locking differentials could be an interesting idea, but then you’d have control problems where the motors would be fighting each other across a single locked axle.
Good explanation, thanks.
It’s less about sending the same power (or torque, really) to every wheel (which is closer to what an unlocked differential does – each wheel gets the same torque), and about sending the right amount to the right wheel. If 2 tires lift and have no traction, you want to send no power (again, torque) there because any amount of torque will make the wheel spin. But if one of the two remaining tires is on sand and the other is on rock, you want to send the right amount of torque to each to get the car moving forward without spinning either tire. There’s never really a case where you want equal power or torque to every wheel.
Then you move forward a foot and all the conditions change and suddenly the tires in contact are different and you need a different amount of torque at each wheel.
Continually applying the same amount of power to a free-spinning wheel would result in it spinning very rapidly until it re-establishes contact with the ground, at which point a lot of things in the drivetrain would be subject to an almighty shock load. Never mind the risk of having a wheel spinning at 60 MPH in midair, potentially with people nearby.
When this came up previously, someone mentioned you might be able to do this with stepper motors, but I don’t think anyone uses stepper motors in EVs. I assume there’s some drawback to using those for an automotive scenario.
These are the only EV’s I really see offroad in Utah (I don’t see any of the Jeep hybrid-electrics, and the latest 4Runner hybrid is rare enough I don’t see too many of them either).
And they do reasonably well as long as it hasn’t rained recently. That 7000-pound curb weight – closer to 8000 pounds when you’ve got two people and stuff inside it – is double what the very common 4Runners, XJ’s, and proper old Cherokees put down. Mud is distinctly ungenerous to these, as is inertia; watching a Rivian try to get downhill after some of the latest storms was absolutely brutal to watch (and I imagine, terrifying for the driver) in comparison to 20+ year old SUV.
Call me simplistic, but it looks to me like just two motors and a couple of lockers is the better answer.
So, about that 1025 horsepower…
I was hoping for a challenge video where you tried to change the direction of the air vents through the touchscreen whilst rock crawling.
If at first you don’t succeed, destroy all evidence that suggests you tried.
Rivians are competent off-road, but are they any fun?
To me, the fun of four-wheeling is working with the machine. You’re more wearing the car than driving it. Horse and rider as one.
All these control systems create a layer of abstraction between driver and machine. Now you’re not working with the car; you’re instead giving it commands and watching the machine perform the request.
If off-road terrain is standing between you and a destination, this works great. If mucking around off-road is the destination, I dunno man.
Can you guys just stop with the embedded Instagram clips? They just show up as blank, unclickable white space on my screen.
Agreed 100%. I don’t subscribe to any Meta products. There’s got to be another way
They work fine for me a the videos play without having to go to instagram.
My PCs are locked down a bit. Probably enough to break some things.
Never mind the horsepower, I just love the rims!
There is something European 70ies over them, reminds me of Dunlop Peugeot or Cromodora Fiat 🙂
I wonder how much better the original quad-motor R1S you drove would be with all the updates Rivian has sent down the pipeline since then? Comparable to the current generation R1S?
It’ll be interesting to see if they keep improving on the off-road performance and how much applies to the more modest dual- and triple-motor configurations
David, you and I really got to get together on this topic. I’ve been doing a ton of homework into this type of control loop traction logic, including writing some custom code. I would love to do a deep dive.
What was the reason I thinked?
I also hate those clickbait headlines!
But if some AI has statistics showing they generate clicks, we’re probably not going to get rid of them 🙁
This is a SOLVED problem. Rivian’s software guys need to take a look at a modern CNC control from Siemens or Fanuc.They’ve been able synchronize two (or more) motors and keep them in lock-step for 30+ years now, even with wildly different and varying loads on them. You can even “virtually gear them”, and have one motor run at a fixed ratio compared to another
You have a “control signal” that demands all of the motors rotate to a constantly changing certain angular position (352° > 353° > 354°, you get the idea), and then each motor has their own servo loop to get the motors to that angular position. That’s how the CNC machines do it, and assuming Rivian has accurate position encoders/resolvers on their motors, they should be able to implement something like this.
They should be able to simulate locked axles this way.
This!!
This is absolutely the way. The way I understand Rivian’s system is that they’re trying to reinvent the 4wd system, when by their own admission their control system can’t work fast enough to accomplish that goal.
It seems to me that it’s much simpler to electronically “lock” all 4 motors together all the time as you describe (the theoretical goal of diff locks). Rivian’s USP would now be that as soon as the system detects the conditions for “driveline binding” (which is why unlocked differentials exist), the system works as it currently does to maintain traction as best it can while allowing different wheel speeds. No need for switches or levers or mode selections; just press the throttle and you have as much traction as you could get in all conditions.
There are reasons CNC machines cost hundreds of thousands to millions of dollars, and the sensors, controls, and motors are part of that.
But even setting aside cost, the required performance, motion profiles and duty cycle/life cycle of a CNC motor is drastically different than an EV motor, and I’m sure there are tradeoffs Rivian is making that limit their ability to control off-road driving in order to optimize range, on-road behavior, etc.
There is nothing special about a CNC machine electric motor. It’s a permanent magnet BLDC motor, just the same used in most EVs. Modern EV motors have accurate position encoders/resolvers necessary to make this happen.
This isn’t crazy complicated. You could do it even simpler than I described: You feed each motor the exact same frequency, and then each motor has its own control loop determining the amount of excitation current needed based on slip. Since they’re BLDC motors, they have no choice but to all rotate at the exact same speed.
CNCs are going to be running servos or steppers which would solve this problem but kill the range. If you want to build a rock crawling EV steppers would be pretty easy to do this with but you wouldn’t want that on the road.
I know this ain’t what this article is about, and I know Toyota bringing a tarted-up Hilux Champ to America for promotional reasons means little, but I just had to say (yet again… sorry) that I wish Toyota would eventually let US buyers have a Hilux Champ in some way. I can only assume it was not engineered with US safety regs in mind, so it’ll likely never happen, even if they wanted a truly affordable small truck option in their US lineup.
And Toyota, please also bring the baby FJ to America. Please?
I think it’s legal to import one for off highway or private property use.
The way you described traction and how the drivetrains handle a variety of conditions was super well done; it’s a nuance to rock crawling I hadn’t really thought about. You did a great job communicating such complex systems.
My neighbor has the R1 truck, he says it’s likely going to be his forever car, and previously he swapped cars every few years. It’s definitely the newest brand I’m impressed with, but I will be perpetually baffled why they are sticking w those Mr Krabs running lights.
This is really interesting, in my mind I’d assumed the 4 motor variant would give the ultimate control over traction but hadn’t thought through how those coordination issues would work.
Of course when I was younger and off roading in the mountains of Montana the real scary situations usually happened going downhill, or around muddy side hills. Ive wondered how much the extra weight of something like a Rivian impacts this. And with 4 motors does it have some version of low range crawl gears? That’s a lot of weight to point down a muddy or snowy incline or do the electric motors create enough drag to allow for pleasantly chill descents?
The embedded video above showing the wheels spinning backward while trying to slow down in loose, downhill conditions was a little unsettling. I’d hate to see that behavior crop up in slick mud, ice, or snow.
Yeh doesn’t seem like fun.
Let me know when you need an editor. I love you all, been a voracious consumer of content from way back when. Too many mistakes that make it to “print”
Hey, the typos prove we don’t use AI! 😉
Soon to be seen at a mall near you.
Did you mean Buc-ee’s?
What really makes the Rivian impressive is not that it’s a good off-roader, it’s that it is both a good off-roader and a tire-shredding drift missile. Does anyone need that? No, but it is impressive.
100%. The thing is a supercar.
It’s not a super car, as that implies on road only. I’d say it’s a supervehicle as it does so many things well. I was definitely surprised to see how good the R1T suspension system really was, glad this R1S has gotten that. Now I will never be able to afford either one so it matters little.
It’s a supercar because it’s loaded with ergonomic compromises.
Too true!
One of the first thing alot or the more off road / snow rivian people do seems to be to throw some Nokian tires on. There is a lot of sensor data and algorithms happening in the backgoud. I guess it doesn’t matter all that much the systems were tuned to the factory tire. But that’s always something thats always in the back of my mind with these systems. I think out of spec did some kind of test with previous gen Rivans and different tires off road.
If they have an option to not use one pedal driving, that may alleviate the negative drive on the tires and shift the braking to the… brakes?
AFAIK Rivian’s do not have the option to turn it off. It’s one of the reasons I cancelled my R2 reservation.
Wow, why wouldn’t they add that as a option? There isn’t any extra hardware needed just coding some software. Lazy coders?
In case anyone is curious about what is meant by a “PID gain loop”, PID stands for Proportional, Integral, Derivative. It is a control scheme that uses feedback for continuous control adjustments, and the PID portion is used to tune how the adjustments are made based on that feedback. It is used heavily in industrial control systems, which is my domain, and in automotive, which is definitely not my domain.
https://en.wikipedia.org/wiki/PID_controller
My first tech job was for a company that made electronic temperature control systems for plastic injection molding machines. The PID parts of the controllers were what made it all so effective at keeping the plastic at the right temp as it was being melted and squeezed through the injectors and into the mold. It was a great first job, and I’m glad I remembered that acronym as soon as I saw it. One of our biggest customers at that time was Ford, using it for their plastic bumpers. Another big one was IBM, using it for the keys on a keyboard for a PC.
I remember decades ago getting excited when smaller microcontrollers started having PID loops built into them, as at the time only beefier programmable logic controllers (PLC) and distributed control systems (DCS) had the processing power to handle that type of control. Suddenly you could put PID-enabled temperature controllers on anything and having right, linear temperature control instead of the janky, semi-binary control of a glorified temperature switch that existed before. These days PID is taken for granted and nothing special, but those of us that were around before it is was everywhere remember just how challenging stuff, like injection and extrusion molding, could be due to the lack of tight control on temperatures and pressures. It’s an unsung hero of the modern world that nobody knows about…or at least that’s what we process control engineers tell ourselves.
That does surprise me that it was actively applying negative torque while descending the grade and not just letting it regen and use the friction brakes while at such a low speed.
It’s nice that these press junkets exist so there can be photographic evidence that someone used their electric suv off road.
Not exactly “their” electric SUV. But I’m all for everyone responsibility off roading any vehicle.
This wasn’t a press junket, but rather a media vehicle I used to do some off-roading with a friend.
Would only having 400BHP motors make the batteries last longer? I don’t really understand why anyone needs 1000 hp in their tall station wagon anyways and it seems like having less would be beneficial to range. Perhaps it’s only impactful to range if you floor it all the time. Still, I don’t get it.
My gut says the industry is trying to out-Macho the ICE guys with bigger numbers in order to make EVs cool or at least grudgingly acceptable. Logic and common sense in motor sizing may appear after some movement in that direction. Or, it may happen after EV makers find that they can’t sell all that many thousand horsepower EV’s. Time will tell.
One actual reason for big hp and torque numbers: What if one or two wheels are spinning? Need some extra torque at the remaining wheels in that scenario.
In principle, bigger motors means more cross sectional area in the motor windings, so for the same amount of total current through the motor, the current is lower in any one part of the windings, leading to less resistive loss, meaning yes, more range.
Also, making a battery that’s capable of fast-charging also makes it good at fast-discharging as a byproduct,
and once you’ve done that, you’ve already done the most expensive step of making a high-output EV drivetrain.
And because the EV drivetrain is already going to be expensive regardless, they might as well upgrade the handful of extra components in order to make it stupidly powerful, to justify the bigger price tag.
All of this I did not know. EV’s expose a gap in my knowledge that’s pretty big.
Right? If you want something that will really cook your brain, start trying to read up on Gaussian Splatting.
My brain just can’t.
I believe that you also get more regen capability from the higher HP system, wasting less energy heating friction brakes, increasing range.
FWD works better for regen than RWD. Same reason why front brakes work better than rear brakes. And why AWD is the best drivetrain layout for a sporting EV.
Without all the driveline complications, RWD BEVs make no sense to me. AWD FTW!